Jaeyeul Kim
I am an assistant professor in the Division of Computer Engineering and Artificial Intelligence at Pukyong National University (PKNU), Busan, South Korea, where I lead the Robot Vision Lab.
Before joining PKNU in September 2026, I was a postdoctoral researcher at DGIST, South Korea, working on autonomous driving with Prof. Sunghoon Im at the DGIST Computer Vision Lab, where I received my Ph.D. in February 2026.
Specifically, I have worked on LiDAR-based segmentation, detection, tracking, and forecasting. My current research interest is in autonomous vehicle planning. From April to October 2024 I was a visiting researcher at the Robotics Institute, Carnegie Mellon University, Pittsburgh, US.
News
- Sep 2026Joined the Division of Computer Engineering and Artificial Intelligence at Pukyong National University as an Assistant Professor, starting the Robot Vision Lab.
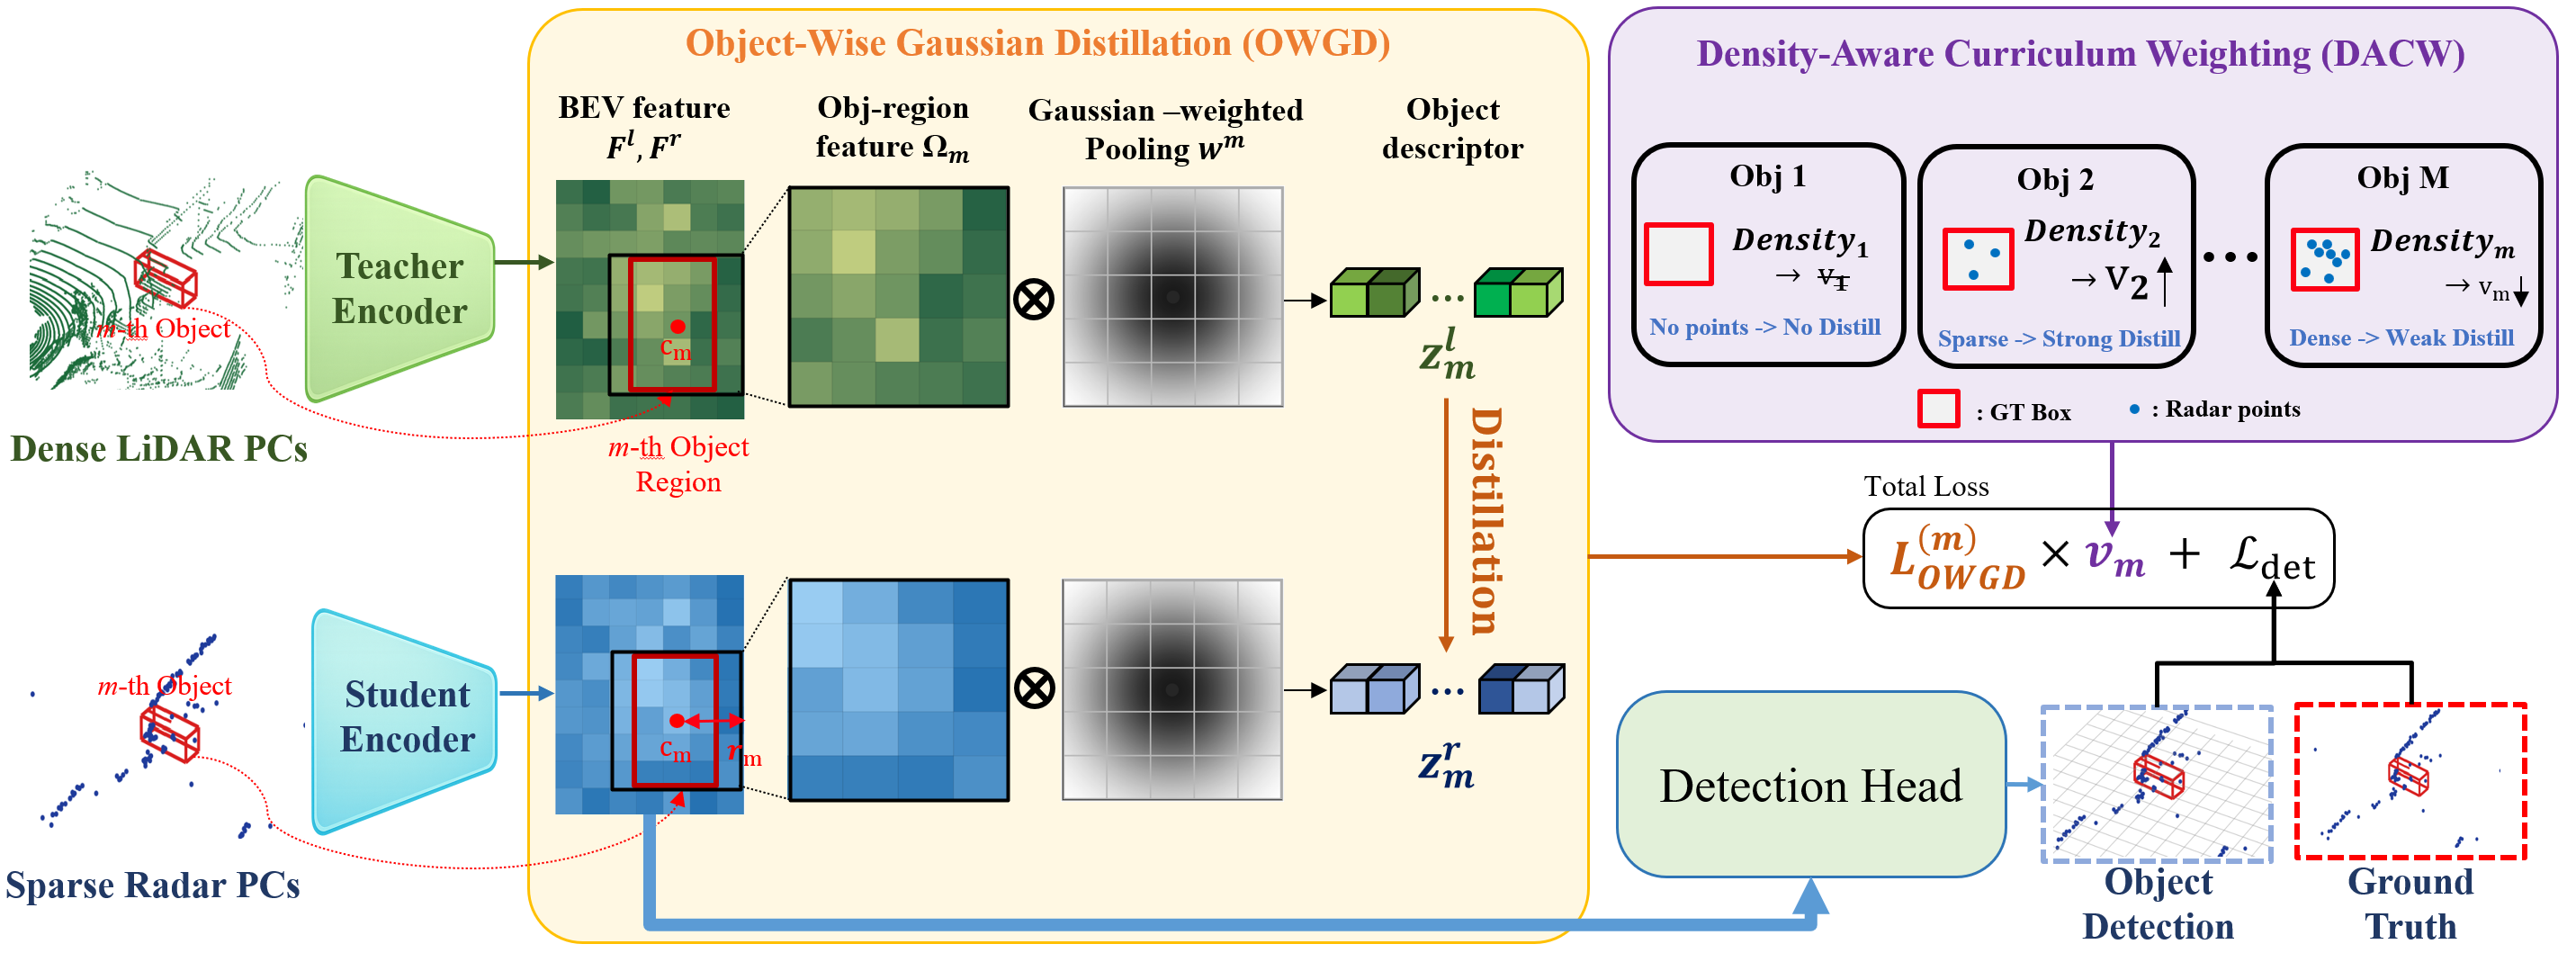
- Aug 2026Object-Centric LiDAR-to-Radar Distillation accepted to IEEE Signal Processing Letters (SPL).
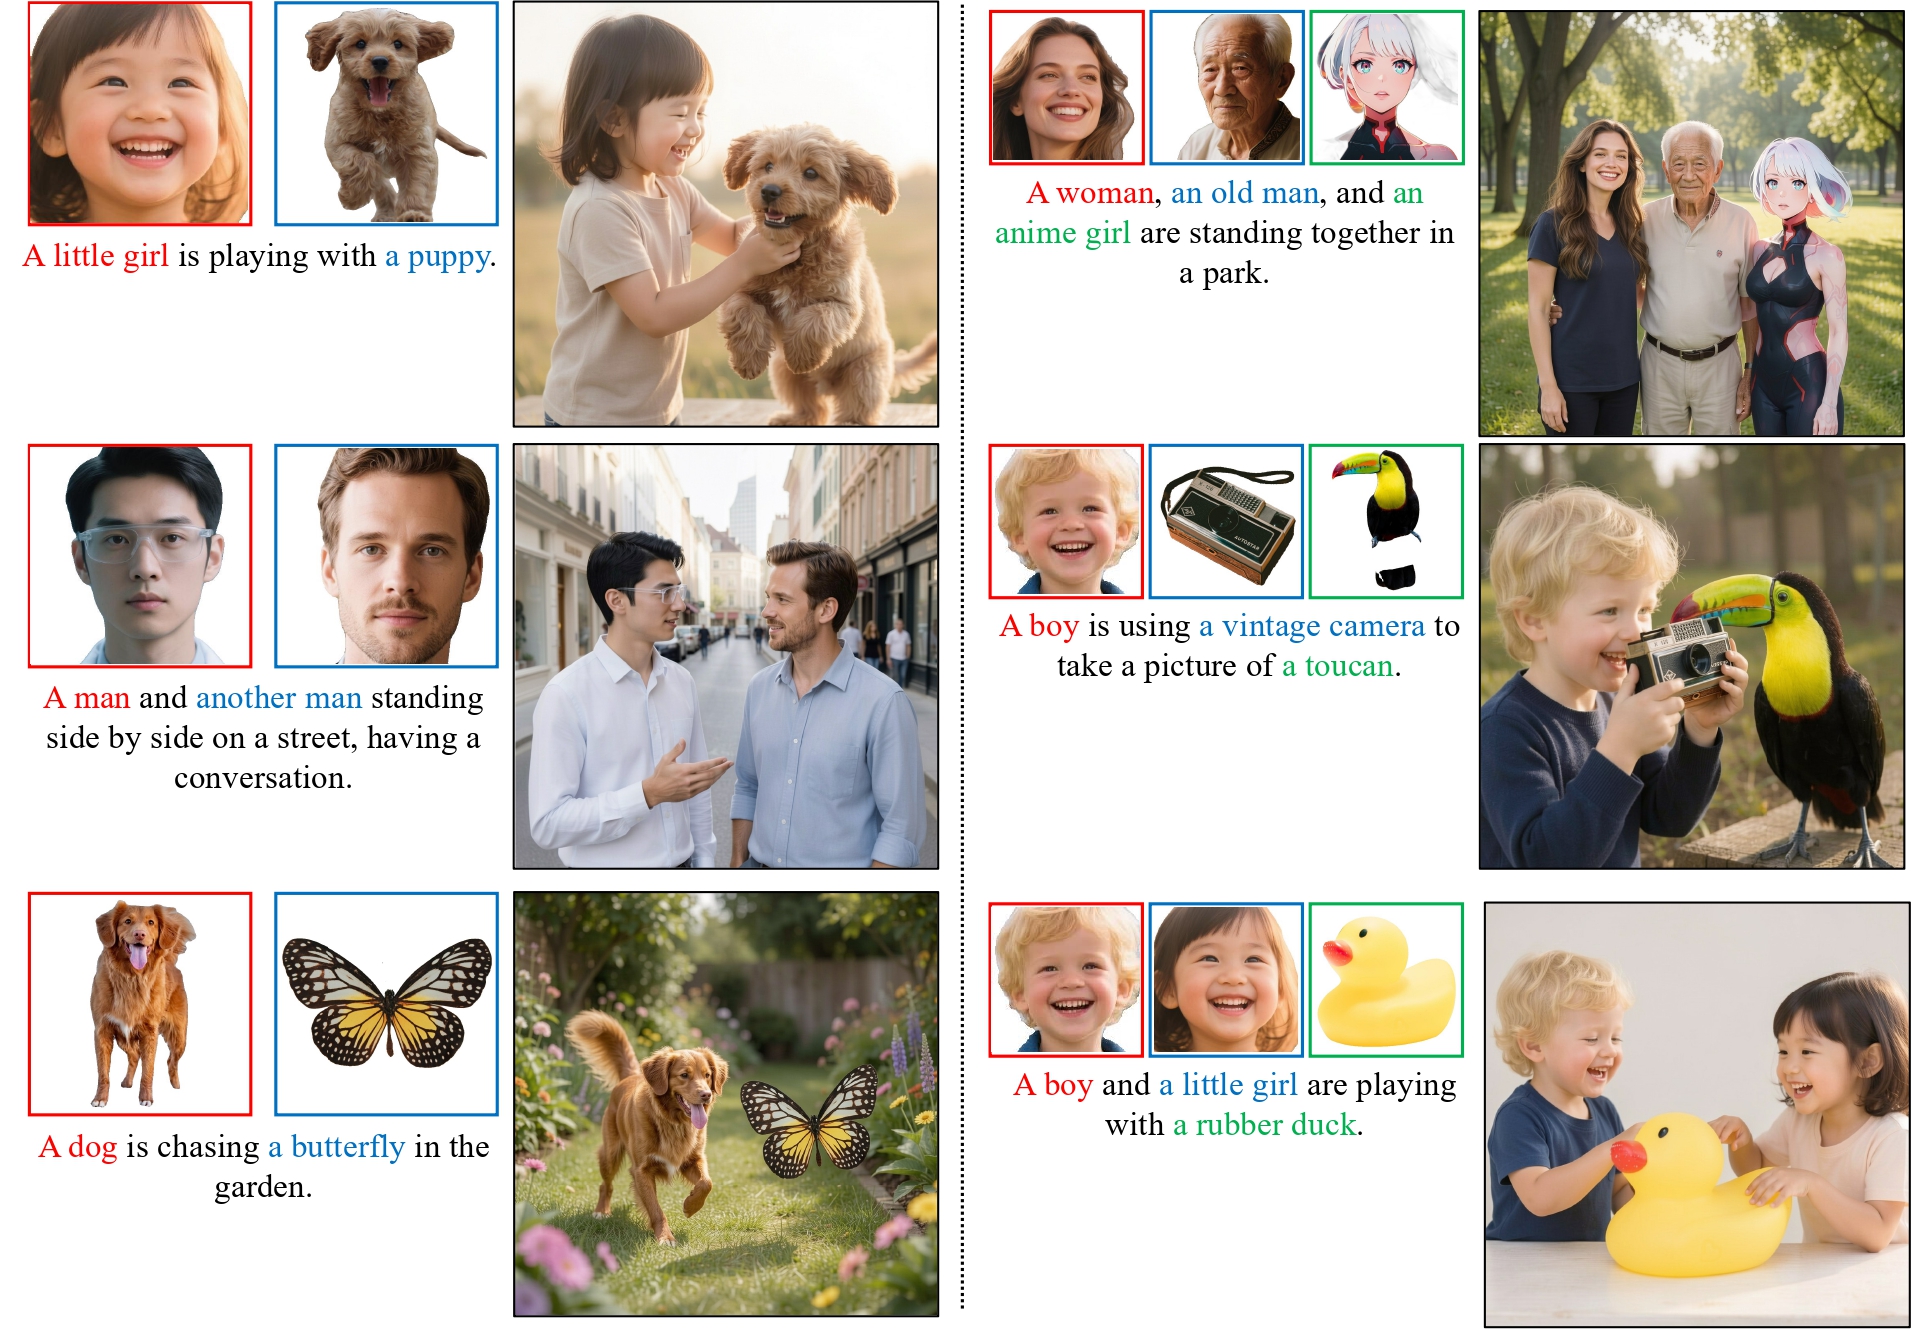
- Jul 2026CRAFT accepted to SIGGRAPH Asia 2026 as an oral paper.
- May 2026One paper accepted to ACM Transactions on Multimedia Computing, Communications, and Applications (TOMM).
- Mar 2026CascadeOcc accepted to IEEE Signal Processing Letters (SPL).
- Feb 2026Two papers accepted to CVPR 2026.
- Nov 2025Infinite-Story accepted to AAAI 2026 as an oral paper.
- Oct 2025Received the Grand Prize in the Next-Generation Engineering Researcher program, IPESK (한국이공학진흥원).
- Jul 2025One paper accepted to the ICCV 2025 Workshop.
- Feb 2025Flow4D accepted to IEEE Robotics and Automation Letters (RA-L / IROS).
- Feb 2025Received the Bronze Award (Outstanding Paper Award) at IPIU 2025.
- Oct 2024Received the Outstanding Research Award from EECS, DGIST.
- Jul 2024One paper accepted to ECCV 2024.
- Jun 2024One paper accepted to IROS 2024.
- Jun 2024Winner of the Argoverse 2 LiDAR Scene Flow Challenge at CVPR 2024 WAD.
- Apr 2024Started a Visiting Researcher position at the Robotics Institute, Carnegie Mellon University (Apr. 2024 – Oct. 2024).
- Jan 2024Received the DGIST Post-Graduate Research Abroad Award.
- Oct 20231st place, Autonomous Driving A.I. Challenge (organized by MOLIT, 국토교통부).
- Jul 2023One paper accepted to IEEE Access.
- Jun 2023Honorable Mention, Argoverse Forecasting Challenge at CVPR WAD 2023.
- Feb 2023Received the Best Robot Vision Paper Award from the Asian Federation of Computer Vision (AFCV).
- Nov 20222nd place, Autonomous Driving A.I. Challenge (organized by MOLIT, 국토교통부).
- Oct 2022One paper accepted to IEEE Access.
- Oct 20223rd place, ECCV Workshop on 3D Perception for Autonomous Driving.
- Jun 2022RVMOS accepted to IEEE Robotics and Automation Letters (RA-L / IROS).
- Aug 2021Started the Ph.D. course in EECS at DGIST.
- Aug 2021Awarded the DGIST Presidential Fellowship.
Publications
* indicates equal contribution. † indicates the corresponding author.
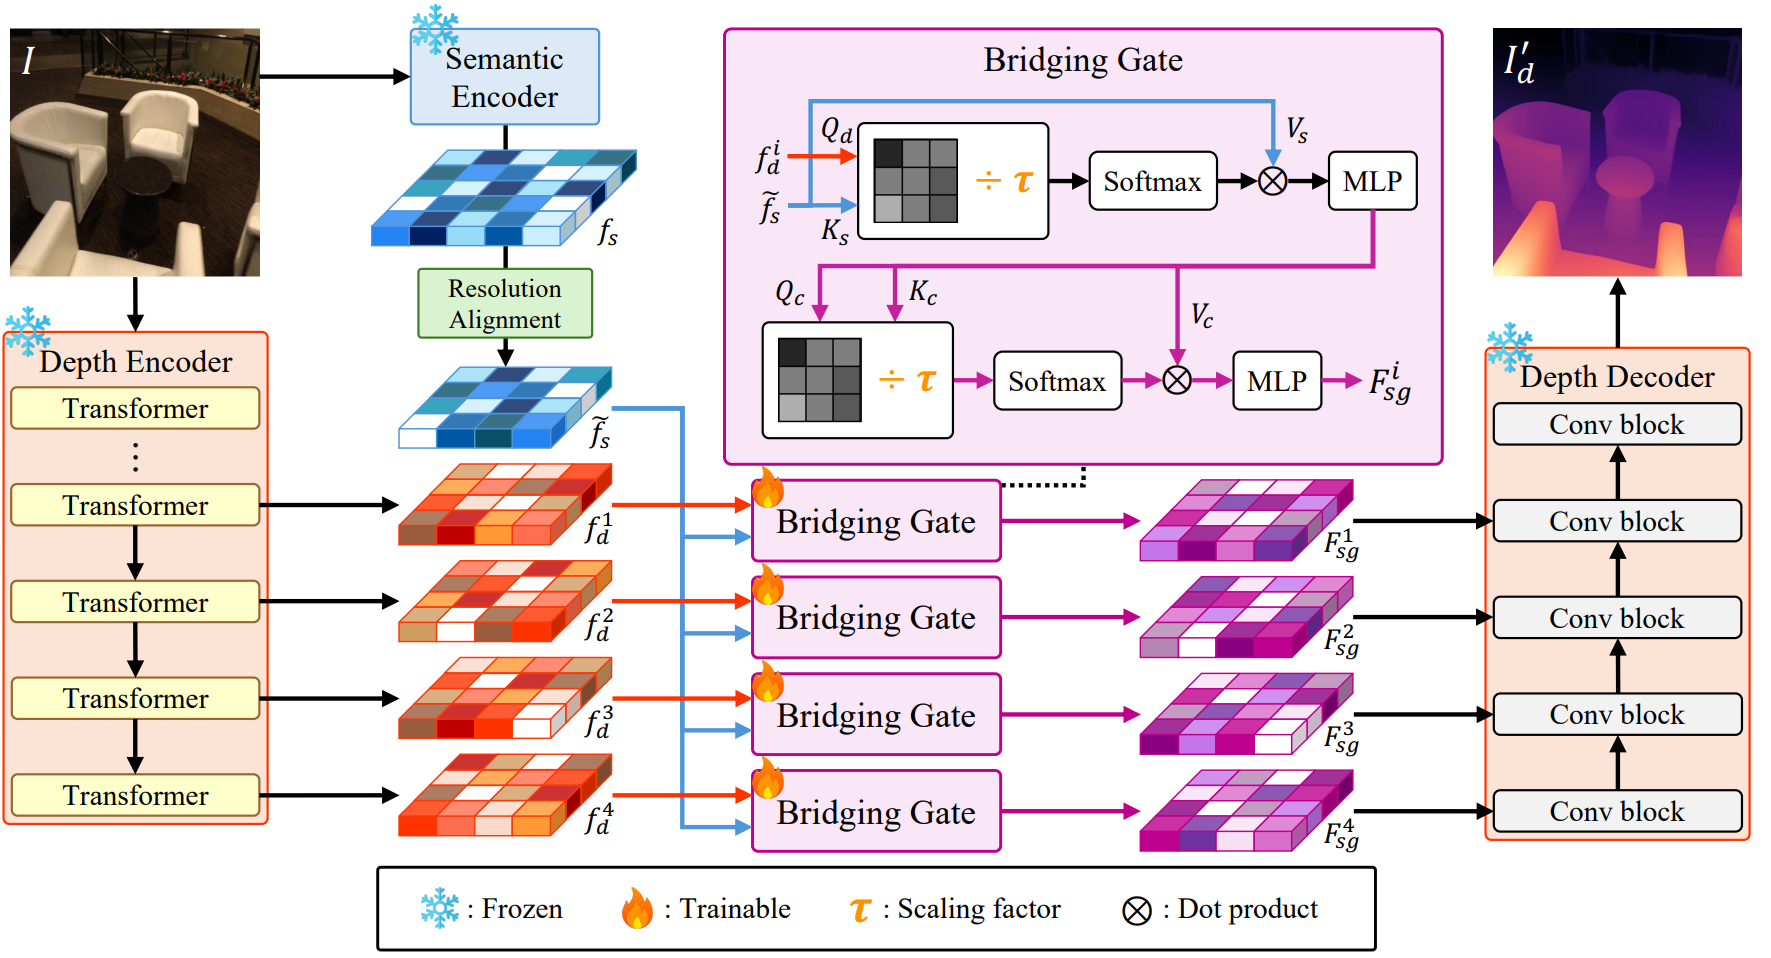
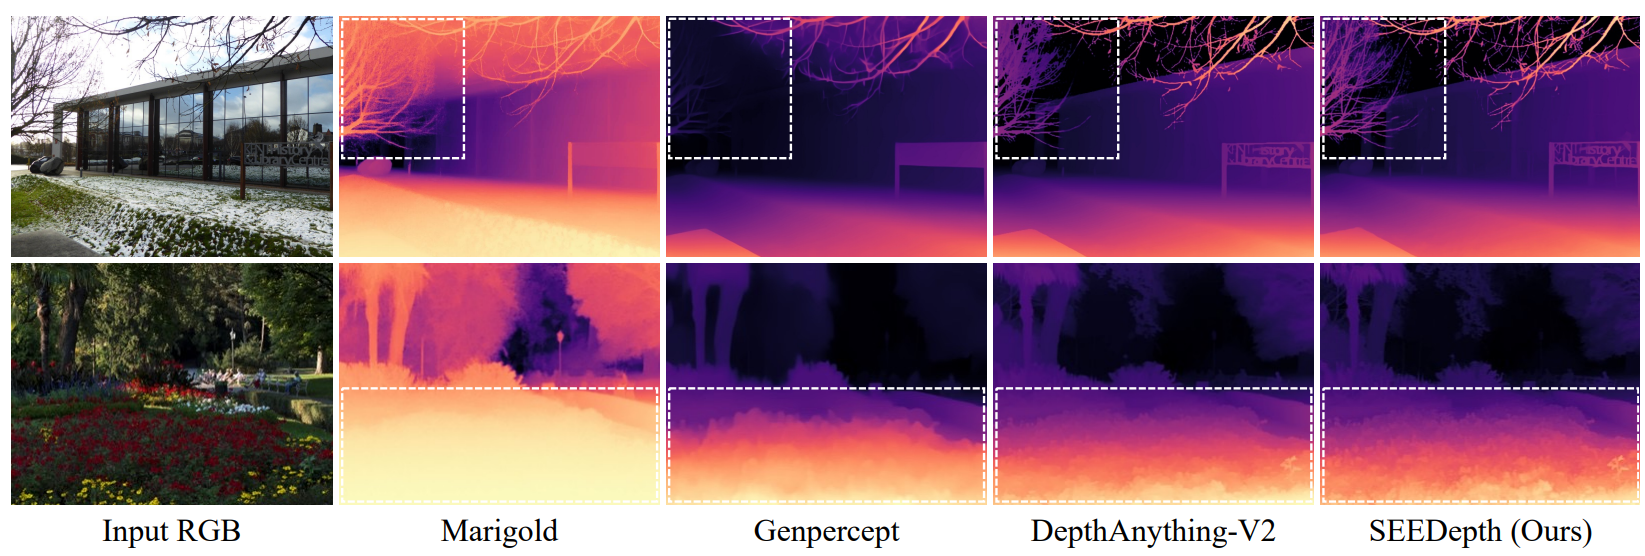
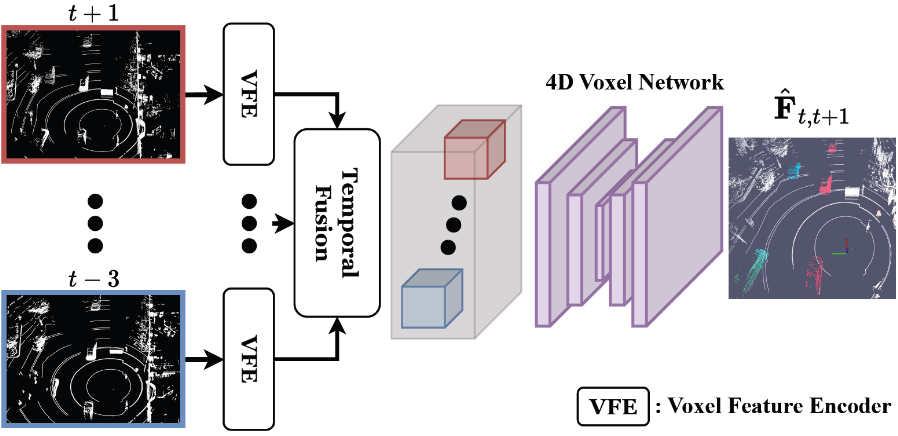
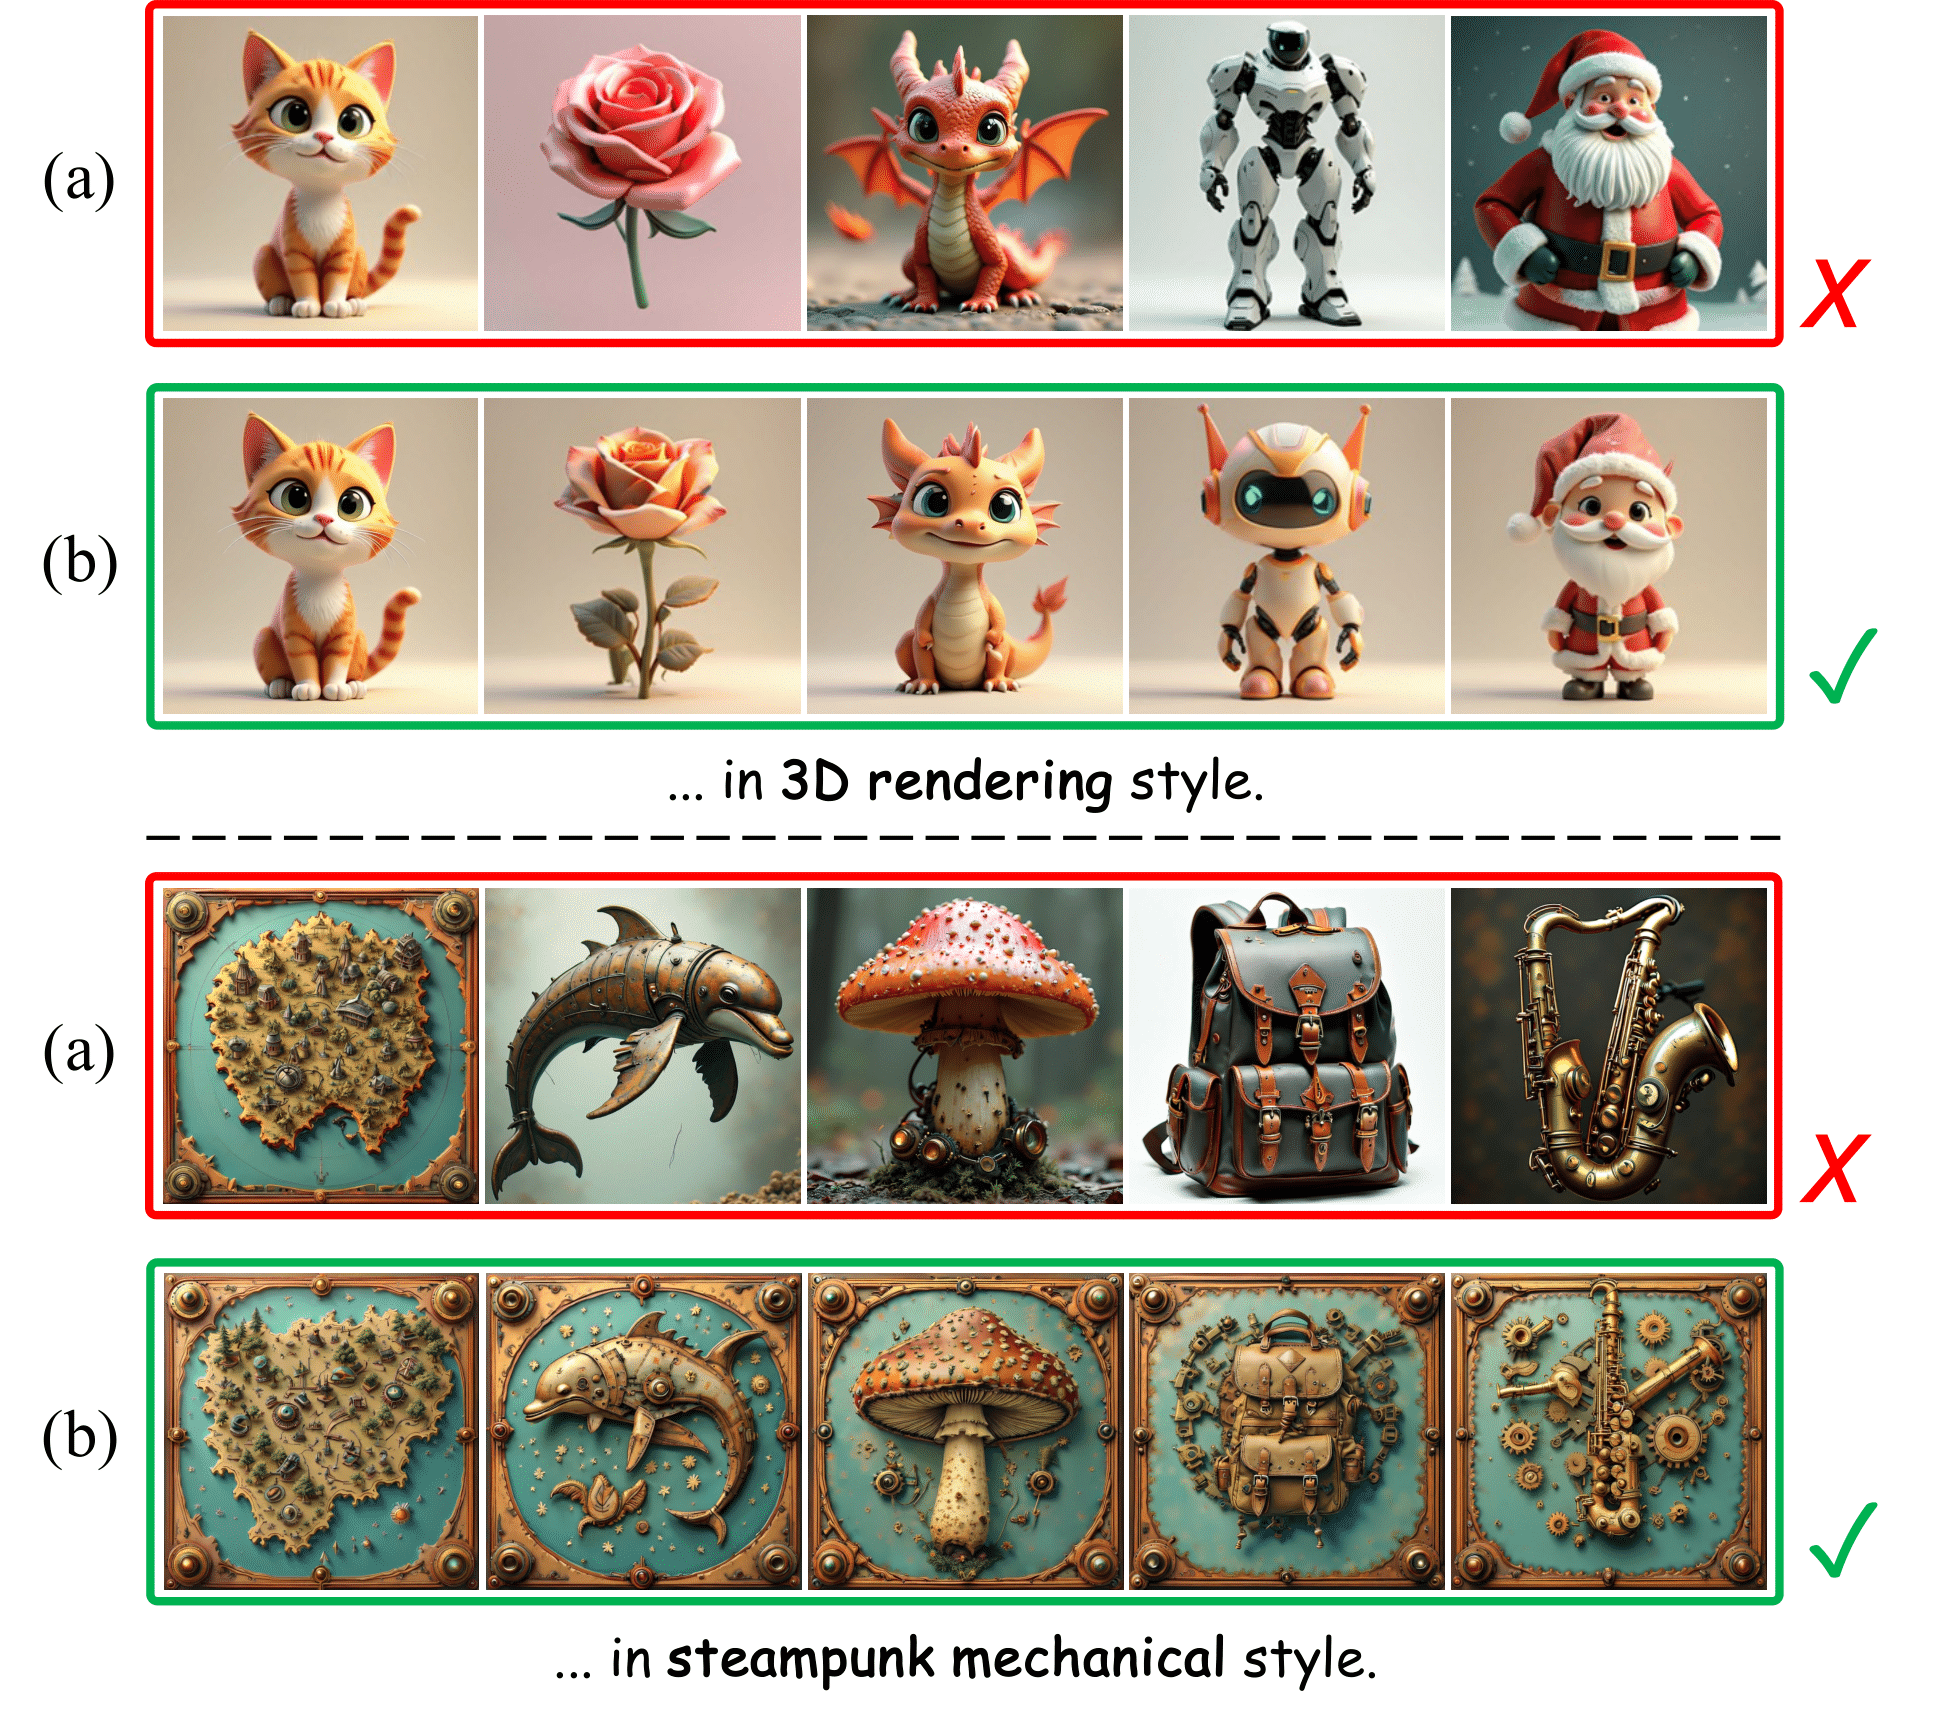
Education & Research Experience
Assistant Professor
Division of Computer Engineering and Artificial Intelligence, Pukyong National University (PKNU), Busan, South Korea
Sep. 2026 – Present
Postdoctoral Researcher
Daegu Gyeongbuk Institute of Science and Technology (DGIST), South Korea
Feb. 2026 – Aug. 2026
Visiting Researcher
Robotics Institute, Carnegie Mellon University (CMU), Pittsburgh, US
Apr. 2024 – Oct. 2024
Ph.D. in Electrical Engineering and Computer Science (Advisor: Sunghoon Im)
Daegu Gyeongbuk Institute of Science and Technology (DGIST), South Korea
Aug. 2021 – Feb. 2026
M.S. in Automotive Engineering (Advisor: Jongeun Ha)
Seoul National University of Science and Technology (SEOULTECH), South Korea
Aug. 2018 – Aug. 2021
B.S. in Mechanical and Automotive Engineering
Seoul National University of Science and Technology (SEOULTECH), South Korea
Mar. 2012 – Aug. 2018
Academic Activities
- Grand Prize, Next-Generation Engineering Researcher, IPESK (한국이공학진흥원), 2025
- Bronze Award, Outstanding Paper Award at IPIU, 2025
- Outstanding Research Award, EECS, DGIST, 2024
- Winner, Argoverse LiDAR Scene Flow Challenge at CVPR WAD, 2024
- DGIST Post-Graduate Research Abroad Award, 2024 (₩15,000,000)
- 1st place, Autonomous Driving A.I. Challenge (organized by MOLIT 국토교통부), 2023
- Honorable Mention, Argoverse Forecasting Challenge at CVPR WAD, 2023
- Best Robot Vision Paper Award, Asian Federation of Computer Vision (AFCV), 2023
- 2nd place, Autonomous Driving A.I. Challenge (organized by MOLIT 국토교통부), 2022
- 3rd place, ECCV Workshop on 3D Perception for Autonomous Driving, 2022
- DGIST Presidential Fellowship, 2021 (₩24,000,000)
- SEOULTECH Graduate School Admission Scholarship, 2018
- Bronze Award, SoC Robot War-HURO Competition (organized by KAIST SDIA), 2018
- Bronze Award, SoC Robot War-HURO Competition (organized by KAIST SDIA), 2017
- IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)
- IEEE/CVF International Conference on Computer Vision (ICCV)
- European Conference on Computer Vision (ECCV)
- Conference on Neural Information Processing Systems (NeurIPS)
- AAAI Conference on Artificial Intelligence (AAAI)
- British Machine Vision Conference (BMVC)
- IEEE International Conference on Robotics and Automation (ICRA)
- IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- IEEE Robotics and Automation Letters (RA-L)
- IEEE Transactions on Circuits and Systems for Video Technology (TCSVT)
- IEEE Sensors Journal
- Python, PyTorch, MATLAB, C++
- Republic of Korea Air Force, 2012 – 2014